How we take SUNAC from today's TRL 3–4 lab prototype to a TRL 6 field trial with an Indian user force:
a medium-class, all-metal, sensor-complete quadruped built from purchasable parts in 10 months.
Prepared bySudhir Pratap Yadav, Founder
Date8 October 2026
Contactsudhiry@untuai.com · +91 6376984160
10 monthsT0 (funding) to user field trial, with hardware, software and test tracks running in parallel
₹20.8 Llanded BOM for one SUNAC M1, including delivery, import duty and GST
₹48.4 Lhardware for the full trial: 2 robots + one shared field-trial kit
32 kg · 15 kgmass · walking payload; 2.5 m/s max, ≈ 8 km per charge, 2–5 km radio range (targets)
Technology readiness path
TRL 3Concept & architecture Achieved
TRL 4Lab prototype walks Achieved
TRL 5Metal prototype validated in relevant conditions Month 8
TRL 6System demo with user in field Month 10
TRL 7Operational evaluation by user LoI · 2027
TRL 8–9Qualified, in service Series A · 2028
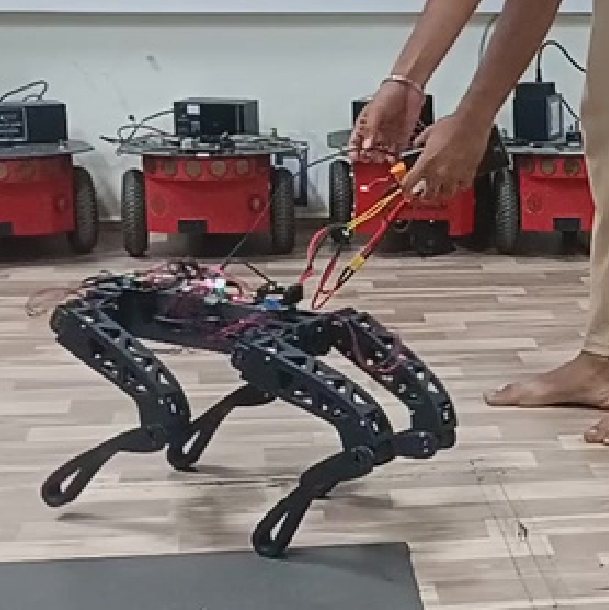
Today · TRL 3–4Lab prototype3D-printed, compact-class, tethered power. It proved our kinematics, control loop and team
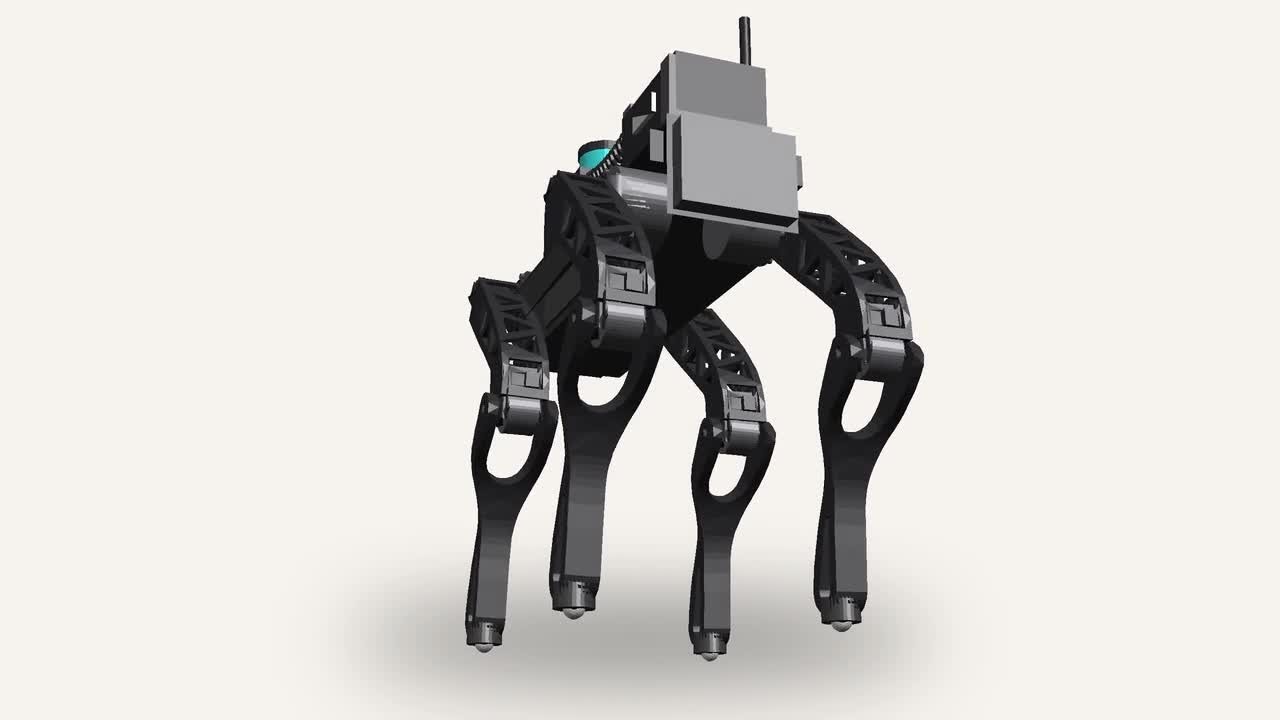
capability, but it cannot carry sensors or survive weather.Next · TRL 5–6SUNAC M1 field prototypeMedium class (Spot/A2 size), welded metal body, 120 N·m QDD actuators,
2× 3D LiDAR, 360° HDR video, 2–5 km MANET radio, 1.2 kWh swappable battery (≈ 8 km per charge), payload port.
The plan in one paragraph
We stop iterating on the printed lab robot and build two SUNAC M1 units in the medium class, the segment
where Spot and Unitree A2 sell and where Indian forces need a robot that carries a real sensor payload but still fits in a
patrol vehicle. The design follows a proven open-source recipe (University of Tokyo's MEVIUS2: e-commerce-sourced,
sheet-metal welded, 13k USD BOM) and upgrades it to a field spec: stronger knees, sealing, tactical IMU, NavIC-capable
RTK, encrypted mesh radio and an independent e-stop. Locomotion is trained by reinforcement learning in simulation
while the hardware is being fabricated, so the robot can walk within weeks of assembly. The trial ends with a TRL 6
report from a user unit (BSF, Army or NDRF), which is the evidence needed for a Letter of Intent.
Working document · prices & specs as of 8 Oct 2026 · planning rate ₹95/USD, ₹110/EURresearch.untuai.com/research/sunac-m1
UNTUAI · SUNAC M1 field-trial planLandscape2 / 6
02 · Existing robots
Three classes of quadruped are being built
Every serious quadruped programme, open or closed, lands in one of three weight classes. The class decides
what the robot can carry, how it is transported and what it costs, so it is the first design decision.
Class A · ≤ 20 kg
Compact / research
Cheap and quick to iterate. Payload under 8 kg, so there is no room for long-range radio, two LiDARs and a mission sensor.
Good for labs and indoor demos. Our printed prototype sits here.
Class B · 20–45 kg
Medium / field utility
Spot-class. Carries a full sensor suite plus 10–25 kg, fits in a Gypsy or Bolero, and two people can lift it.
This is where commercial volume and most defence pilots are today. SUNAC M1 goes here.
Class C · 45–75 kg
Heavy / mule & armed
IP67, 20–40 kg payload, weapon and arm mounts. Needs a hoist or ramp, and each unit lands at ₹1–2 Cr imported.
A later SUNAC variant can reuse the M1 software with larger actuators.
Robot · origin
Mass
Payload (walk)
Max speed
Max step
Peak joint torque
Runtime
IP
Price (approx.)
A · Compact / research ≤ 20 kg · indoor, education, R&D, light inspection
Unitree Go2closedChina
15 kg
~7 kg
3.7 m/s
16 cm
45 N·m
1–2 h
—
$1.6k–15k
MIT Mini CheetahopenUSA
9 kg
—
2.45 m/s
—
17 N·m
—
—
research
ODRI Solo-12openEU
2.5 kg
—
—
—
2.5 N·m
—
—
~$12k
MEVIUS (v1)openJapan
15.5 kg
—
—
—
25 N·m
—
—
~$12k
SUNAC lab prototypeoursIndia
<10 kg
—
—
—
—
tethered
—
TRL 3–4
B · Medium / field utility 20–45 kg · patrol, inspection, CBRN, disaster, light logistics ← our target
Boston Dynamics SpotclosedUSA
33.8 kg
14 kg
1.6 m/s
30 cm
85 N·m
1.5 h
IP54
~$75k
Unitree A2closedChina
37 kg
25 kg
3.7 m/s
30 cm
180 N·m
3–5 h
IP56
~$32k
MEVIUS2 (2026)openJapan
22.9 kg
—
—
—
60 N·m
~1 h
—
$13k BOM
SUNAC M1 (this plan)oursIndia
32 kg
15 kg
2.5 m/s
25 cm
180 N·m
2–2.5 h
IP54→65
₹20.8L BOM
C · Heavy / mule & armed 45–75 kg · max payload, weapon & arm mounts, all-weather
Unitree B2closedChina
60 kg
40 kg
6 m/s
40 cm
360 N·m
4–6 h
IP67
$77k–110k
DEEP Robotics X30 ProclosedChina
~59 kg
20 kg
4 m/s
20 cm
—
2.5–4 h
IP67
quote
Ghost Robotics Vision 60closedUSA
51 kg
10 kg
3 m/s
—
—
~3 h
IP67
quote
ANYbotics ANYmal DclosedSwitzerland
50 kg
15 kg
1.3 m/s
25 cm
—
1.5–2 h
IP67
~$150k
Figures come from vendor and reseller spec sheets and the MEVIUS2 paper (arXiv 2603.22031, Table I). Sources disagree in places,
so treat them as approximate. Max speed is the vendor figure (Go2, A2 and B2 also quote higher lab/burst speeds). Spot torque is the average over its range of motion; B2 torque and step are knee and obstacle figures. "—" means not published.
Why medium is the right next step
Payload headroom: 15 kg covers 2 LiDARs, a MANET radio and a thermal or CBRN module. A compact robot cannot carry this.
Logistics: two-person lift, carried in a standard patrol vehicle. Heavy-class robots need a ramp and a dedicated vehicle.
Cost: our BOM is about ₹21 L against roughly ₹40 L landed for an A2 and ₹90 L+ for a Spot. Heavy class lands at ₹1–2 Cr.
De-risked: MEVIUS2 has shown an e-commerce-sourced metal build at this size, with the design published.
Scales both ways: the same stack can shrink to a light scout or grow into a heavy mule.
Indian landscape (for positioning)
Army MULE: 100 units procured in an emergency tranche in 2023.
Zen Technologies, Prahasta: weapon-mountable, LiDAR + RL terrain mapping.
Svaya Robotics: domestically designed demonstrator with DRDO, on the IDDM track.
Bhairav, Shvana: armed UGV/quadruped, 5–8 km LTE/RF link.
None of these claims 100% indigenous hardware. The winning claim is Indian design IP plus an Indian software stack (Buy Indian-IDDM, ≥ 50% IC).
Working document · prices & specs as of 8 Oct 2026 · planning rate ₹95/USD, ₹110/EURresearch.untuai.com/research/sunac-m1
UNTUAI · SUNAC M1 field-trial planOur robot3 / 6
03 · Our robot
SUNAC M1: medium-class field prototype
Design targets for the two field-trial units, to be verified at the M3–M6 milestones. Sized to beat Spot on payload,
speed and endurance, match the Unitree A2 on torque, and stay buildable from parts we can buy today.
Platform
Class
Medium / field utility (Spot · A2 size)
Mass
32 kg ± 3 incl. battery · ≈ 26 kg body, two-person lift
Size
≈ 900 × 480 × 600 mm standing · ≈ 300 mm high sitting
Actuation4× CAN buses → 12 QDD actuators, 1 kHz PD
Safety MCUe-stop radio · contactor · BMS · watchdog
Power48 V 1.2 kWh → pre-charge → DC-DC 19 / 12 V
CommsMANET mesh ↔ OCU: video, map, commands
Payload port48 V · 12 V · GbE · CAN · PPS
Against the benchmarks
SUNAC M1 (target)
Boston Dynamics Spot
Unitree A2
MEVIUS2 (open)
Mass
32 kg
33.8 kg
37 kg
22.9 kg
Payload (walk)
15 kg
14 kg
25 kg
—
Max speed
2.5 m/s (2.0 sustained)
1.6 m/s
3.7 m/s (5 burst)
—
Max step · slope
25 cm · 30°
30 cm · 30°
30 cm · 45°
—
Runtime
2–2.5 h
1.5 h
5 h (3 h @ 25 kg)
~1 h
Range per charge
≈ 8 km (5 km @ 15 kg)
—
20 km (12.5 km @ 25 kg)
—
Battery · charge
1.2 kWh swap · 3 h
564 Wh swap · 2 h
907 Wh hot-swap · 1 h
≈ 230 Wh LiPo
Comms (standard)
MANET 2–5 km + e-stop radio
Wi-Fi (radio add-on)
Wi-Fi 6 · 4G option
Wi-Fi
IP · temperature
54→65 · −10/+50 °C
54 · −20/+45 °C
56 · −20/+55 °C
—
Peak joint torque
180 N·m
85 N·m
180 N·m
60 N·m
Unit cost
₹20.8 L BOM
~₹90 L+ landed
~₹40 L landed
~₹12 L BOM
Design IP
Indian
US
China
open (JP)
Radio range depends on terrain and antenna height; ground-to-ground figures are targets measured at M4 and in the trial. Competitor data: vendor/reseller sheets; "—" = not published.
Working document · prices & specs as of 8 Oct 2026 · planning rate ₹95/USD, ₹110/EURresearch.untuai.com/research/sunac-m1
UNTUAI · SUNAC M1 field-trial planBill of materials4 / 6
BOM: one SUNAC M1 + field-trial kit
Prices checked 8 Oct 2026. Total = unit × qty + delivery + duty/GST. Indian prices include GST except rows with a GST
figure (18% added). Imports ($/€) carry ≈ 28% duty + IGST on items + freight.
EST. = quote-based estimate ·
IN = Indian-made.
B · Field-trial kit(items ₹5,92,225 + delivery + duty/GST)
13,000
60,933
₹6,66,158
₹20.85 LA · landed BOM, one robot
₹6.66 LB · field-trial kit, one-time
₹48.35 LTrial hardware total = 2 × A + B
≈ 28%Indian content by cost (unit 1); design IP 100% Indian
Notes. RobStride is back-ordered in the US, so order in week 1 (alternates: OpenELAB EU, rcdrone $319).
Jetson is priced as a module; the dev kit is ₹4.25 L. Confirm J501 GMSL support for the e-con cameras before the PO. The Mesh Rider price is a dealer listing, so get a model quote.
Lean config (₹30k 4G router instead of MANET, one LiDAR): ≈ ₹17.6 L per robot. At 10+ units: ≈ 30% lower.
Excludes salaries, cloud GPU, test-range fees and certification.
Working document · prices & specs as of 8 Oct 2026 · planning rate ₹95/USD, ₹110/EURresearch.untuai.com/research/sunac-m1
What SUNAC M1 will do on the first day of the field trial, layer by layer. Everything above the hardware is our own software integration,
which is where the indigenous-IP claim and the long-term value sit.
Missionoperator layer
Patrol routes drawn on a map; click-to-go; scheduled sentry and patrol; live 360° HDR video; snapshot and alert log; one operator can run several robots.
Autonomynavigation
Nav2 waypoint following and route patrol · RTK-GNSS + NavIC where the sky is open, LiDAR localisation in GPS-denied tunnels and buildings · geofence · return-to-home on link loss · obstacle avoidance.
Perceptionunderstanding
FAST-LIO2 LiDAR-inertial SLAM builds a 3D map in real time · GPU elevation mapping for footstep-aware walking · person and vehicle detection on Orin (YOLO-class) · change detection on repeat patrols.
LocomotionRL policy
Policy trained in Isaac Lab on thousands of simulated terrains with domain randomisation · walk, trot, stair, crawl and sit gaits · blind and perceptive modes · push and slip recovery · self-righting after a fall.
Controlreal-time
50 Hz policy → 1 kHz joint PD inside each actuator · EKF state estimate (IMU + leg kinematics) · torque, temperature and current limits · battery-aware power budget.
Hardwareplatform
12-DoF QDD legs with 180 N·m knees · 15 kg payload · welded metal body · IP54→65 · 1.2 kWh swappable pack · 2× LiDAR, depth, 4× HDR cameras, tactical IMU, RTK GNSS · encrypted MANET · independent e-stop.
Trial acceptance targets: 2 km autonomous patrol without intervention · ≥ 6 km walked on one charge · 20 cm stairs and 30° slope with 15 kg ·
2 h continuous walking · 2.0 m/s trot · recovers from a push and stands up after a fall · e-stop under 300 ms · live video at 2 km line of sight.
Every module bolts to the top rail and plugs into one standard connector. Each mission kit swaps in minutes, with no new robot.
48 V · 10 A12 V · 5 AGigabit EthernetCAN-FDPPS time syncM6 rail, 15 kg
EO/IR surveillance gimbal640×512 thermal + 30× zoom day camera on a stabilised mast. AI flags people and vehicles at night.
₹4–8 L · BSF · ITBP · SSB
Night-vision kitStarlight low-light camera + 850/940 nm IR illuminator for covert navigation and video.
₹0.5–1 L · Army · CAPF patrols
Long-range 3D LiDAR32-channel, 200 m LiDAR for corridor and border mapping and tunnel surveys.
₹4–7 L · Engineers · NDRF
Weapon / RCWS mountRecoil-rated hardpoint for a user-supplied remote weapon station. Fire control stays human-in-the-loop under the user programme; non-lethal payloads come first.
user programme · Army · special forces
CBRN & gas podMulti-gas, VOC and gamma dosimeter with geo-tagged readings on the map. The robot enters the zone first.
Logistics mule kitCargo rack (15 kg), casualty sled tow and auto-follow-me for last-mile supply.
₹0.3–0.6 L · Army · NDRF
Mesh-relay nodeThe robot drops or carries radio repeaters to extend the link into valleys, tunnels and collapsed buildings.
₹2–2.5 L / node · NDRF · Army
Mine / IED sweepFront sweep arm with metal detector + GPR. Marks hits on the map and lets the soldier stay back.
₹3–8 L · Army engineers
Audio & acoustic arrayTwo-way speaker/mic to talk to trapped victims; mic array to localise gunshots and voices.
₹0.5–2 L · NDRF · CAPF
Drone dockBack-mounted landing pad or tethered quadcopter for overwatch. Air and ground recon in one team.
₹2–5 L · BSF · Army
Industrial inspectionThermal hotspots, acoustic leak detection and AI gauge reading on scheduled rounds. Civil revenue for the same platform.
₹2–4 L · Refineries · power · mining
Add-on costs are indicative component ranges. Prefer Indian suppliers where they exist (for example Tonbo Imaging for thermal).
Working document · prices & specs as of 8 Oct 2026 · planning rate ₹95/USD, ₹110/EURresearch.untuai.com/research/sunac-m1
UNTUAI · SUNAC M1 field-trial planTimeline6 / 6
06 · Timeline
10 months to a TRL 6 field trial
Hardware, software and test run in parallel. Locomotion training starts on day one in simulation, so software is
ready when Unit 1 is assembled. Dates assume funds arrive by 1 Nov 2026 (T0); every bar moves with T0.
Autonomy & OCU: waypoint patrol, return-home, video
Test & trial
Lab tests: payload, endurance, fall recovery
Environmental tests: heat, dust, water, cold
Internal field runs: desert (Jodhpur), quarry, hills
User field trial (BSF / Army / NDRF) + TRL-6 report
Milestones
M1M2M3M4M5M6
M1Design freeze · late Dec 2026
M2Unit-1 first walk · early Mar 2027
M3Stairs + 15 kg payload · early May 2027
M42 km autonomous patrol · mid Jun 2027
M5TRL 5 · environment-qualified · end Jun 2027
M6TRL 6 · user field trial done · end Aug 2027
What happens after month 10
Month 10–12: user feedback goes into Rev-B (IP65, hot-swap battery, first payload kit). Push for a Letter of Intent and an iDEX/DISC contract.
2027 H2: TRL 7 operational evaluation with 3–5 units in user hands.
2028: Series A, small-batch production, indigenous actuator in the BOM, ≥ 50% IC for Buy (Indian-IDDM).
Team load (core)
2 mechanical / mechatronics · 1 electronics & power · 2 RL & controls · 1 perception & autonomy · 1 test & field lead,
plus founders on user engagement. Aligns with the ₹1.3–1.5 Cr/yr run-rate plan.
Top risks & mitigations
Actuator supply (China-origin, back-ordered)
Order in week 1 with 3 spares; qualify CubeMars AK80-64 as second source; start an Indian actuator track in parallel (IC lever).
Customs and lead-time slips
Consolidate imports into one shipment; budget 6 weeks; train in simulation while waiting.
Sim-to-real gap in locomotion
Actuator-network modelling, domain randomisation, gantry-protected first walks, staged terrain curriculum.
Actuators only IP52
Sealed body, boots on joints, IP54 for trial; move to RobStride IP67 variants for Rev-B.
Field-trial access
Engage BSF/Army/NDRF and iDEX (DISC 14) from month 1; book trial slot by month 6.
Working document · prices & specs as of 8 Oct 2026 · planning rate ₹95/USD, ₹110/EURresearch.untuai.com/research/sunac-m1